Why the Same RTK Drone Produces Different Accuracy in Different Environments
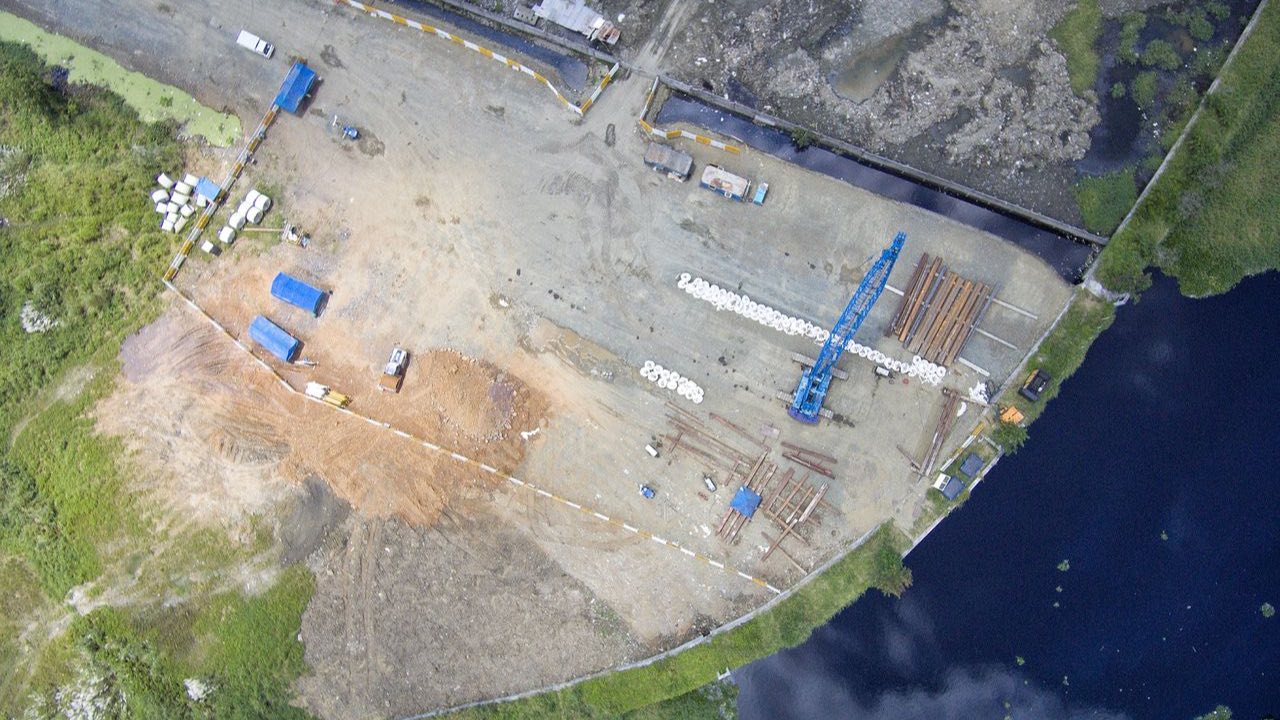
RTK-equipped UAVs have become common enough in mapping and survey work that the technology is no longer considered specialized. A fixed-wing or multirotor with an onboard RTK receiver can produce centimeter-level positional accuracy — in the right conditions. The same hardware, in a different environment, may deliver accuracy no better than a standard GNSS solution without RTK, or may lose fix entirely during a mission.
The hardware isn’t the variable. The environment is. And understanding what changes between environments helps explain why RTK drone mapping projects have such different outcomes across different sites.
What RTK actually depends on
Real-time kinematic positioning works by comparing signals received by the drone’s antenna to signals received at a ground reference station with a precisely known position. The reference station transmits corrections in real time, the onboard receiver applies them, and the result is a position solution that accounts for atmospheric delays and other error sources that degrade standard GNSS.
For this to produce centimeter accuracy, the system needs to maintain what’s called an integer ambiguity fix — a resolved solution for the exact number of carrier wave cycles between each satellite and each receiver. This fix state is stable when the drone antenna has a clear, unobstructed view of multiple satellites across multiple constellations, with strong, consistent signal. When the satellite geometry degrades, or signals are blocked or reflected, the fix can degrade from fixed to float, and accuracy drops from the centimeter range to the decimeter or meter range without any indication in the flight log other than a change in fix status.
Open agricultural fields: the environment RTK was designed for
Open flat terrain is where airborne RTK performs closest to its specification. The drone has unobstructed sky view across a wide elevation angle range, satellite geometry is favorable, multipath reflections from ground surface are predictable and mostly below the antenna’s sensitivity threshold, and the baseline to the ground reference station is typically short relative to the area being surveyed.
In these conditions, an RTK system with a good antenna maintaining fix throughout the mission can deliver horizontal accuracy below 3 cm and vertical accuracy below 5 cm without ground control points. This is the performance figure that gets cited in manufacturer specifications, and in open field conditions it’s genuinely achievable.
The things that can still cause problems in otherwise favorable open conditions: flying a very long baseline from the reference station (beyond 10-15 km, atmospheric conditions at the drone’s location diverge meaningfully from the reference station); strong ionospheric activity, which affects all constellations and is more pronounced at certain latitudes and during solar events; and taking off before the receiver has had time to initialize a proper fix, which results in a float-mode mission that looks correct in the flight log but produces accuracy equivalent to standard GNSS.
Forest edges and partially obstructed environments
Tree canopy and forest edges create a specific pattern of RTK degradation that’s different from complete signal blockage. The branches and leaves attenuate satellite signals selectively — some satellites that are geometrically visible are blocked by foliage, while others are not. The result is a reduced satellite count combined with a geometry that may have large gaps in sky coverage.
The particular problem at forest edges is that the drone transitions between open-sky conditions (high satellite count, strong fix) and obstructed conditions (reduced satellite count, potential fix loss) within the same flight. If the fix is lost over the forest edge and doesn’t recover before the next waypoint, that waypoint is captured in float mode, and the accuracy for that portion of the mission is unknown until post-processing reveals the fix status history.
A RTK GNSS antenna for UAV drone mapping designed to receive across multiple constellations — GPS, GLONASS, Galileo, BeiDou — maintains fix better at forest edges than single-constellation solutions, because it draws from a larger pool of potential satellites. Even when five or six satellites are blocked by foliage, a multi-constellation antenna that was tracking thirty satellites may still have enough geometry from the remaining visible satellites to maintain fix. A GPS-only antenna tracking eight to ten satellites may not.
Urban environments and the multipath problem
Building-dense environments introduce a different failure mode: multipath. When a satellite signal reflects off a building facade before reaching the drone’s antenna, the receiver picks up both the direct signal and the reflected signal. The reflected signal has traveled a longer path and arrives with a slight delay. The receiver, attempting to solve the RTK integer ambiguity, encounters signals that appear to come from slightly different directions than expected, and the solution either degrades in accuracy or cycles through incorrect integer solutions before settling.
In high-rise urban environments, multipath is severe enough that centimeter RTK accuracy may be unachievable regardless of antenna quality. The problem isn’t signal strength — the receiver may see perfectly strong signals from multiple satellites — but signal quality in the form of phase consistency. Signals that have reflected off glass and steel facades are geometrically contaminated in ways that the correction algorithm cannot fully compensate for.
For urban surveys where RTK cannot maintain reliable fix, the alternatives are denser ground control point networks (returning to a GCP-based workflow), post-processed kinematic positioning with data collected in long hover dwell times at key positions, or accepting that the survey will have reduced accuracy in areas of heavy building obstruction and planning the flight path accordingly.
What this means for mission planning
The environment determines the expected RTK performance before the drone takes off. A site assessment that includes identifying forest edges, building heights relative to flight altitude, and baseline distance to the reference station tells a planner where fix is likely to be maintained and where it may degrade.
Adjusting flight altitude to increase the satellite elevation angle above obstructions — flying higher over forest edges, for example — is one planning lever. A drone at 80 meters sees a wider sky window over a 20-meter tree line than one at 40 meters. The improvement in visible satellite count from the additional altitude often more than compensates for the slight decrease in ground resolution from higher flight.
The fix status log from each mission is also worth reviewing as part of the data quality check before delivery. A mission with consistent fixed status throughout is reliable at its specified accuracy. A mission with extended float segments needs either GCPs to constrain those areas or a note to the client about the reduced accuracy in the affected zone.
RTK accuracy is a system output, not a hardware specification. The antenna and receiver determine the ceiling. The environment determines where the result actually lands.